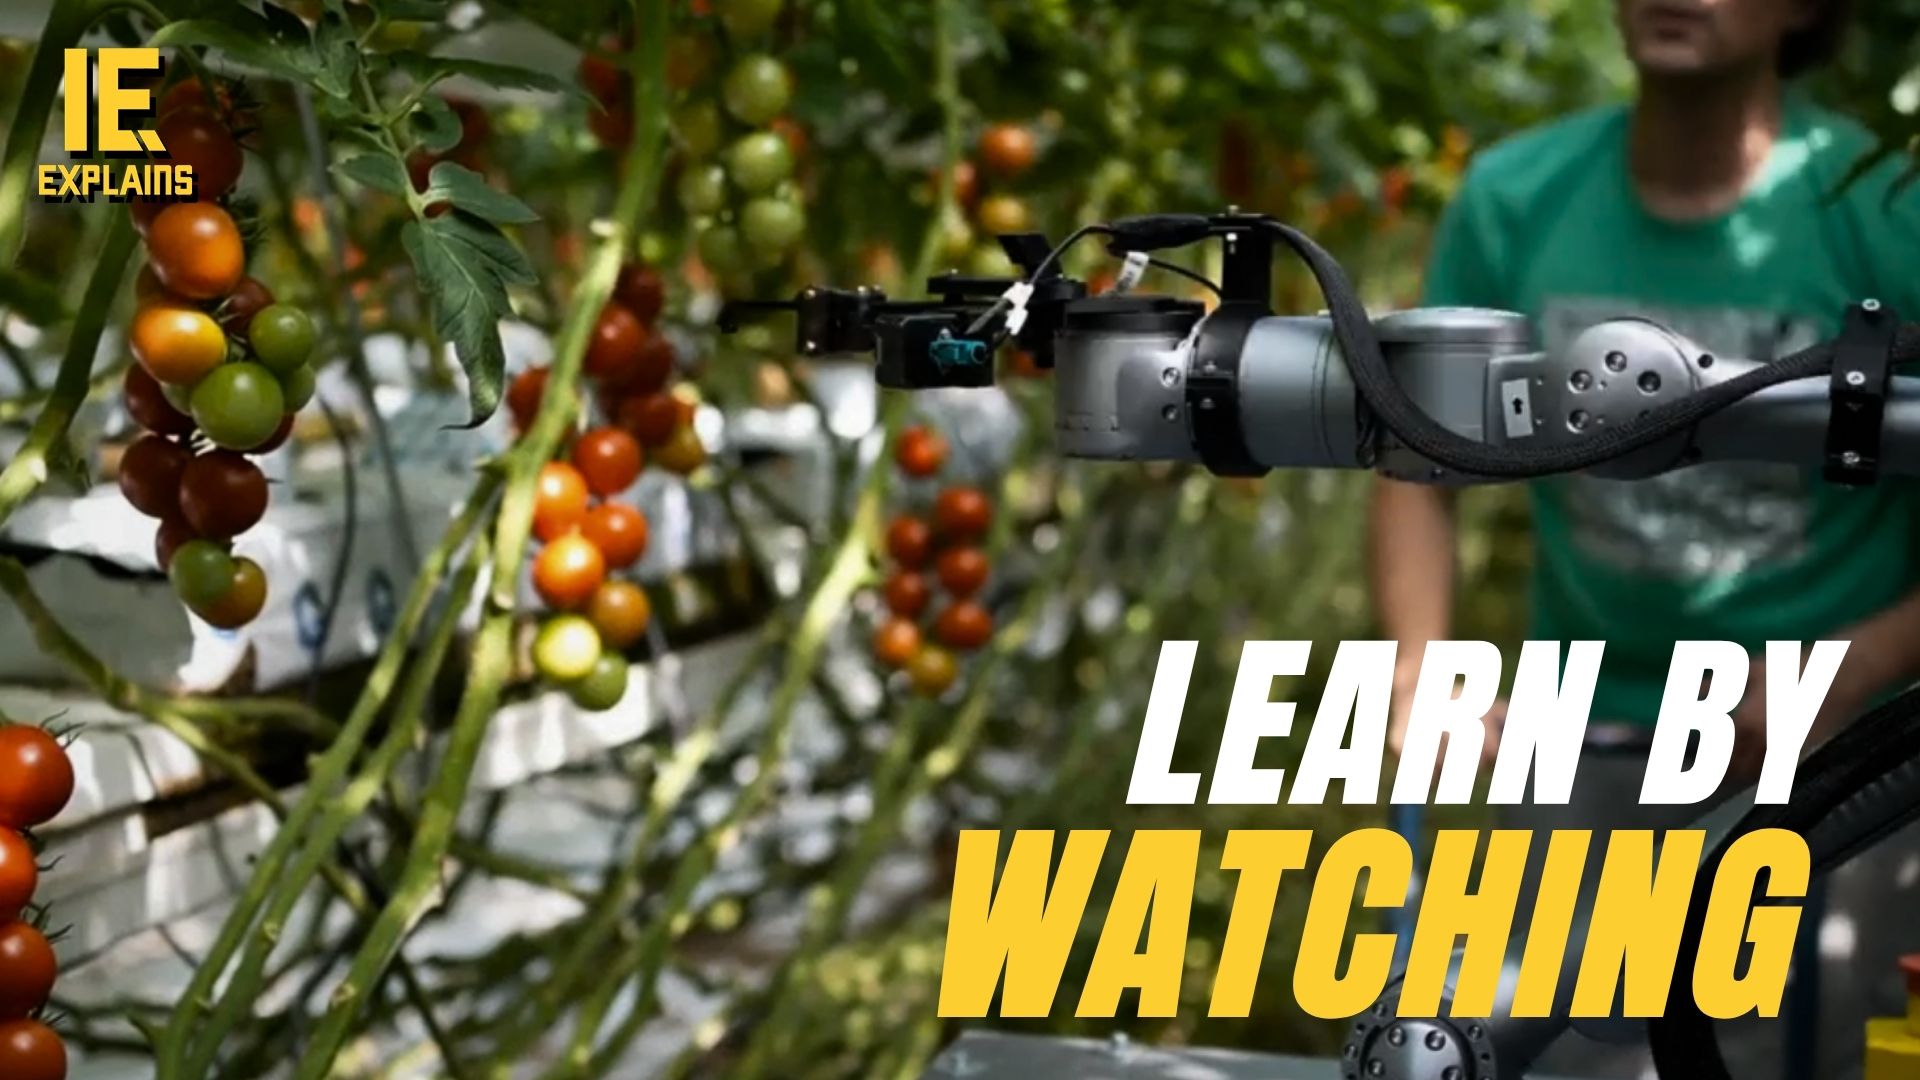
Polybot, a Tubingen startup spun out of the ELLIS Institute and the Max Planck Institute for Intelligent Systems, is building a fully autonomous truss tomato harvester that learns the job end to end from human demonstrations rather than hand written rules. It picked its first tomato on its own in May 2025 and was harvesting full greenhouse rows by December. A full pilot runs in summer 2026, with the first systems due to growers in early 2027.
I
Read full storyInteresting Engineering
Original source